Selected work
Projects
projects — CAD, embedded systems, controls
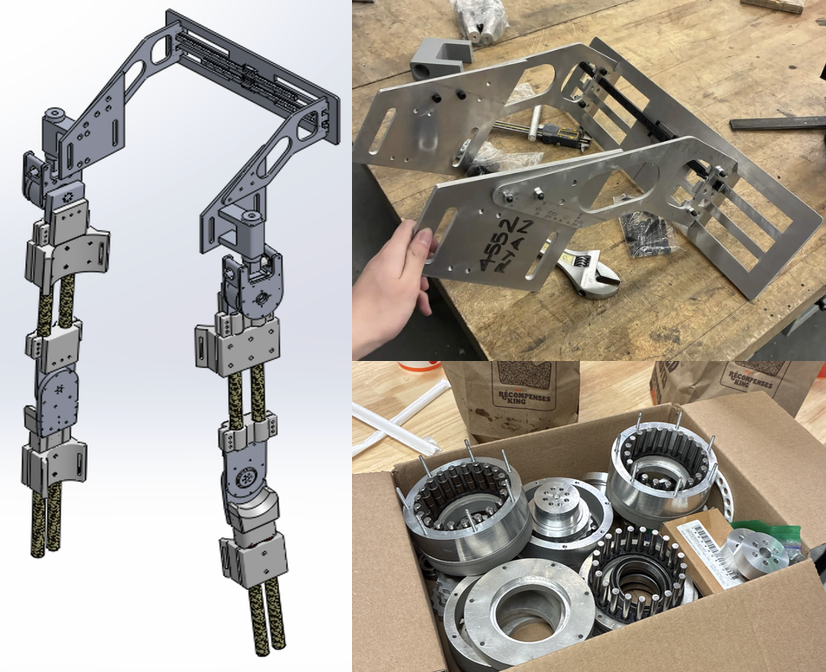
Exoskeleton Work
Mechanical Lead of the Exoskeleton project at Waterloo Biotron.
SOLIDWORKSFEATEAM LEAD
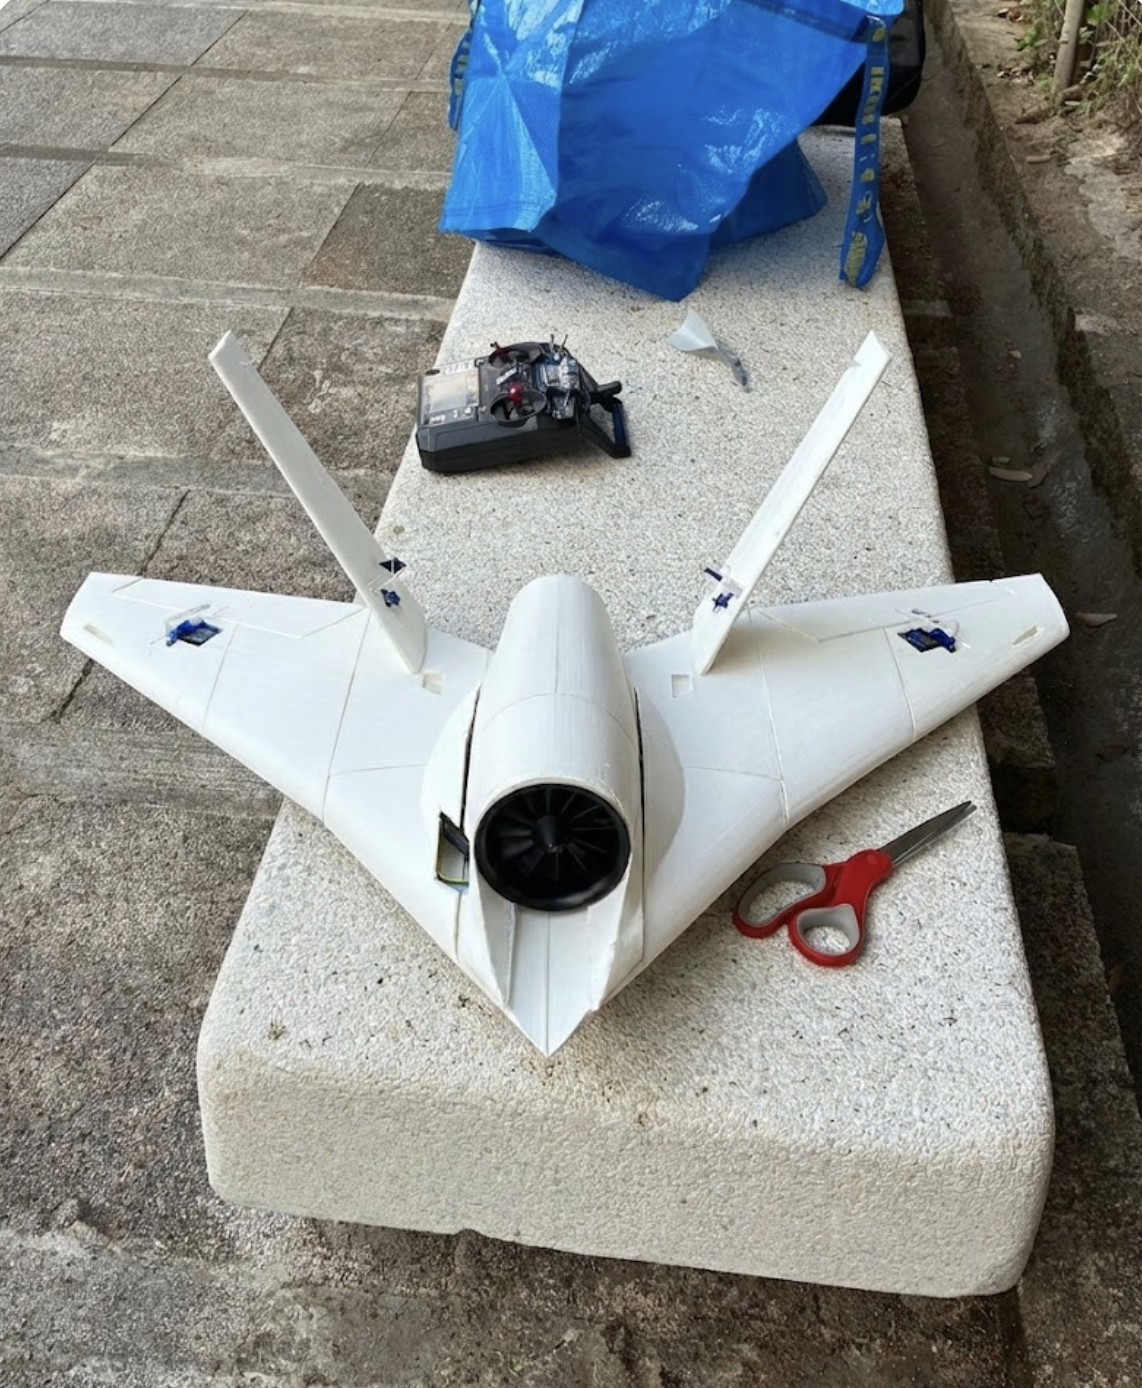
FPV UAV Test Platforms
Various UAVs optimized for efficient flights at medium-to-high cruise speeds.
AERODYNAMICSFLIGHT TESTCAD
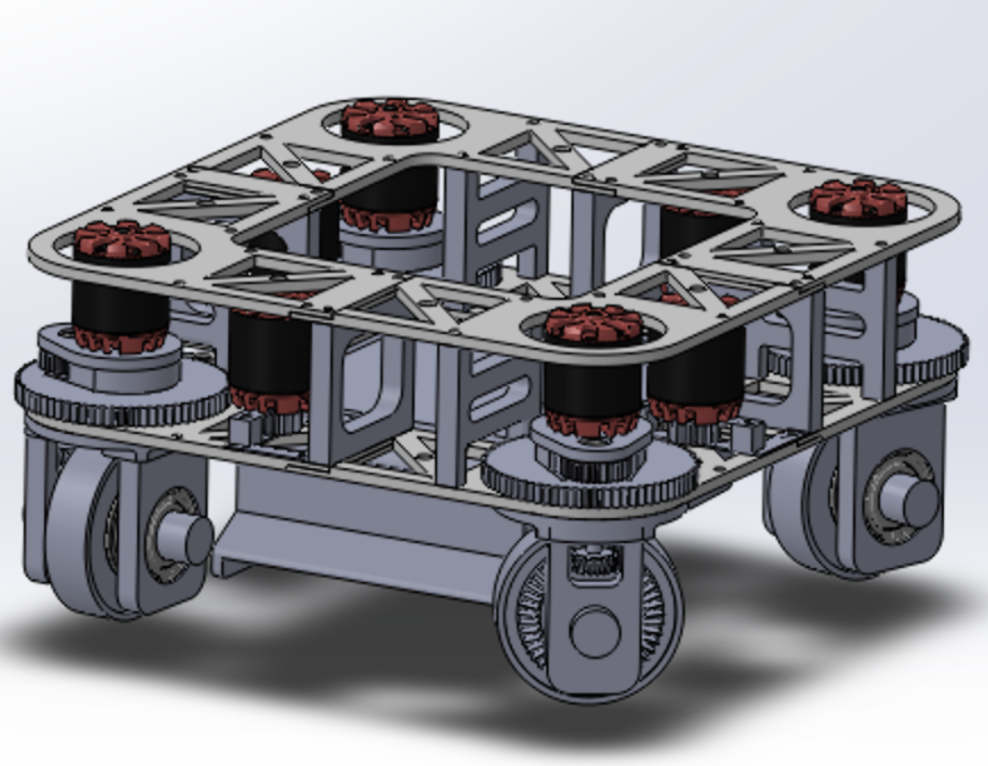
Swerve Vacuum Robot
Autonomous custom robot built for agile, omnidirectional navigation and floor cleaning.
ROS2SLAMA*
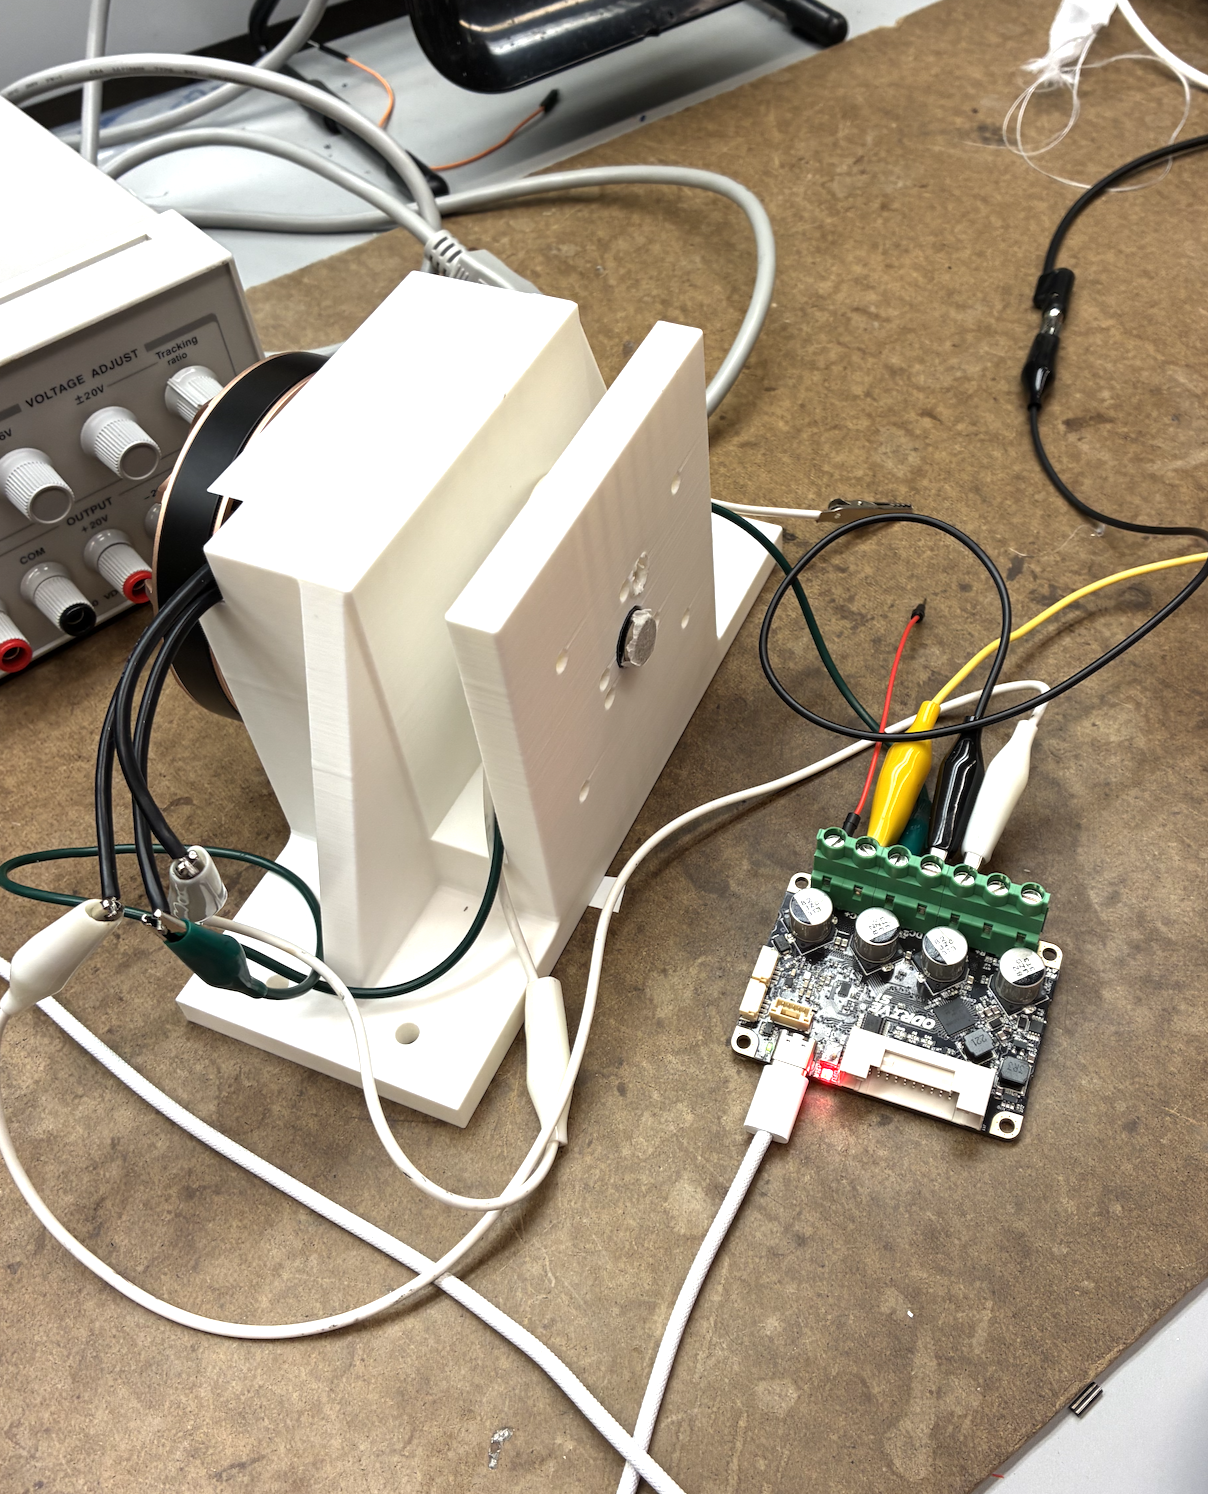
Cycloidal Gearbox Test Rig
A test rig for optimization of Exoskeleton Gearboxes(IN PROGRESS)
ELECTROMECHANICAL DESIGNANSYSHARDWARE INTEGRATION
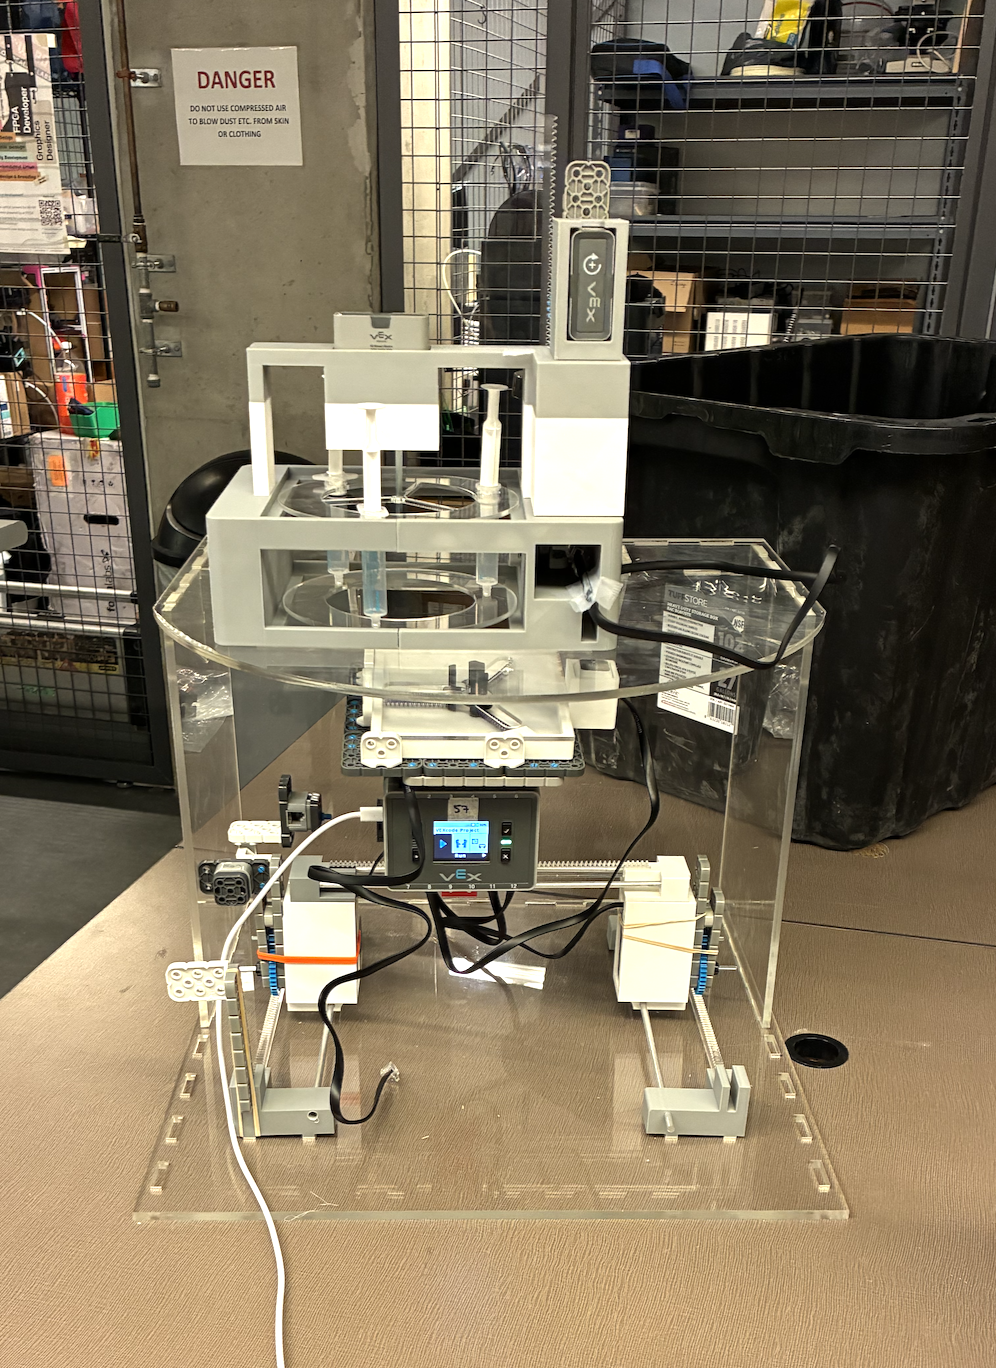
Cookie Icing Printer
An Icing Printer System for cookies designed and built with spare components, lasercutting and 3D printing.
C++AUTOMATIONHARDWARE INTEGRATION
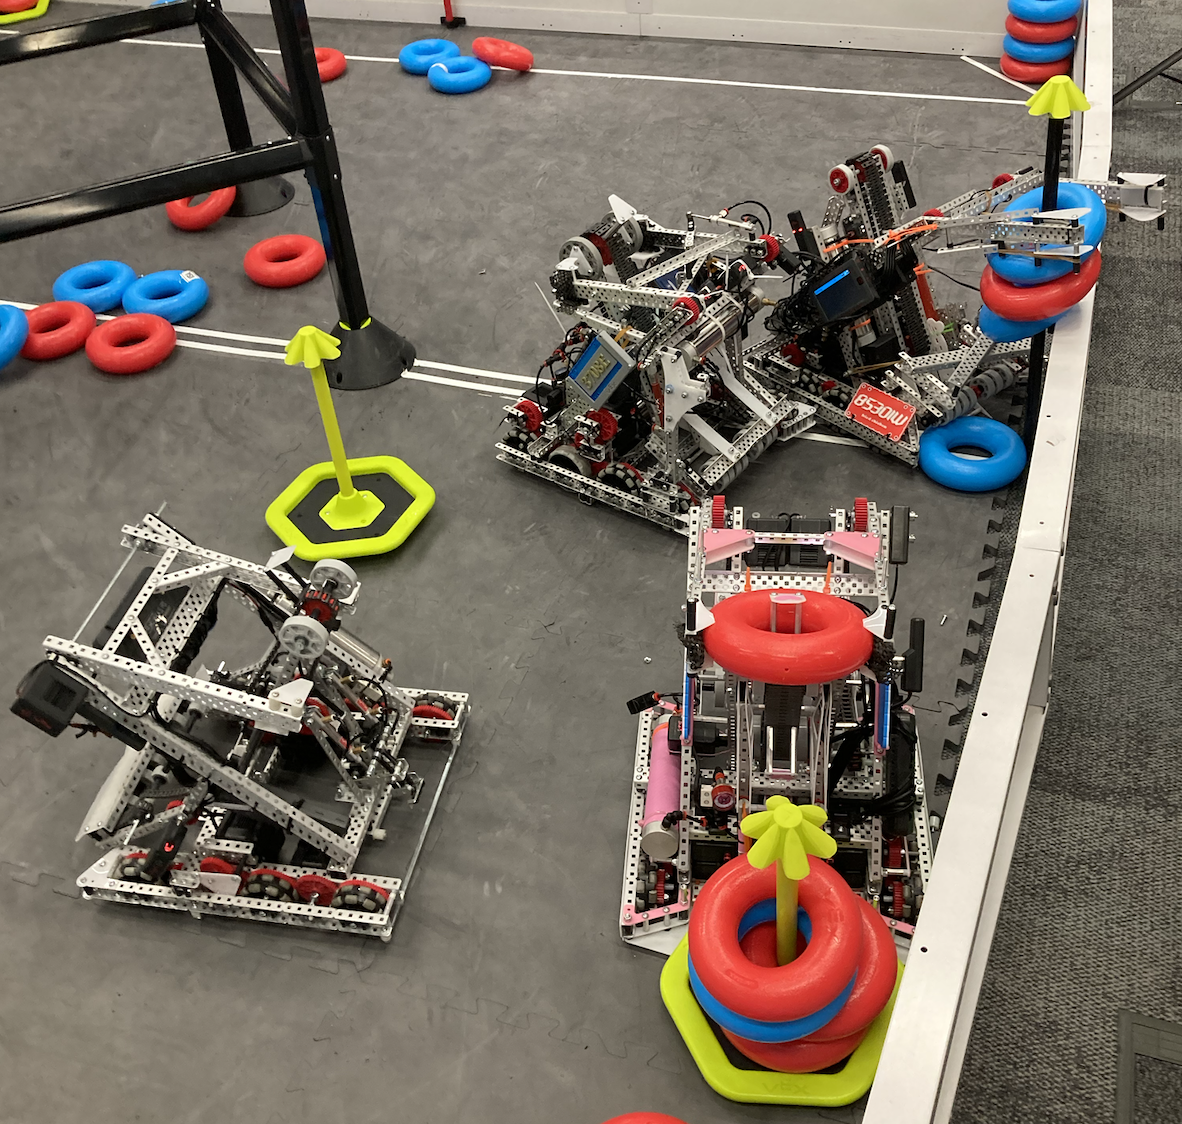
VEX Robotics
Various robots built as Founder and Captain over three competitive seasons.
CADTEAM LEADMECHANISMS
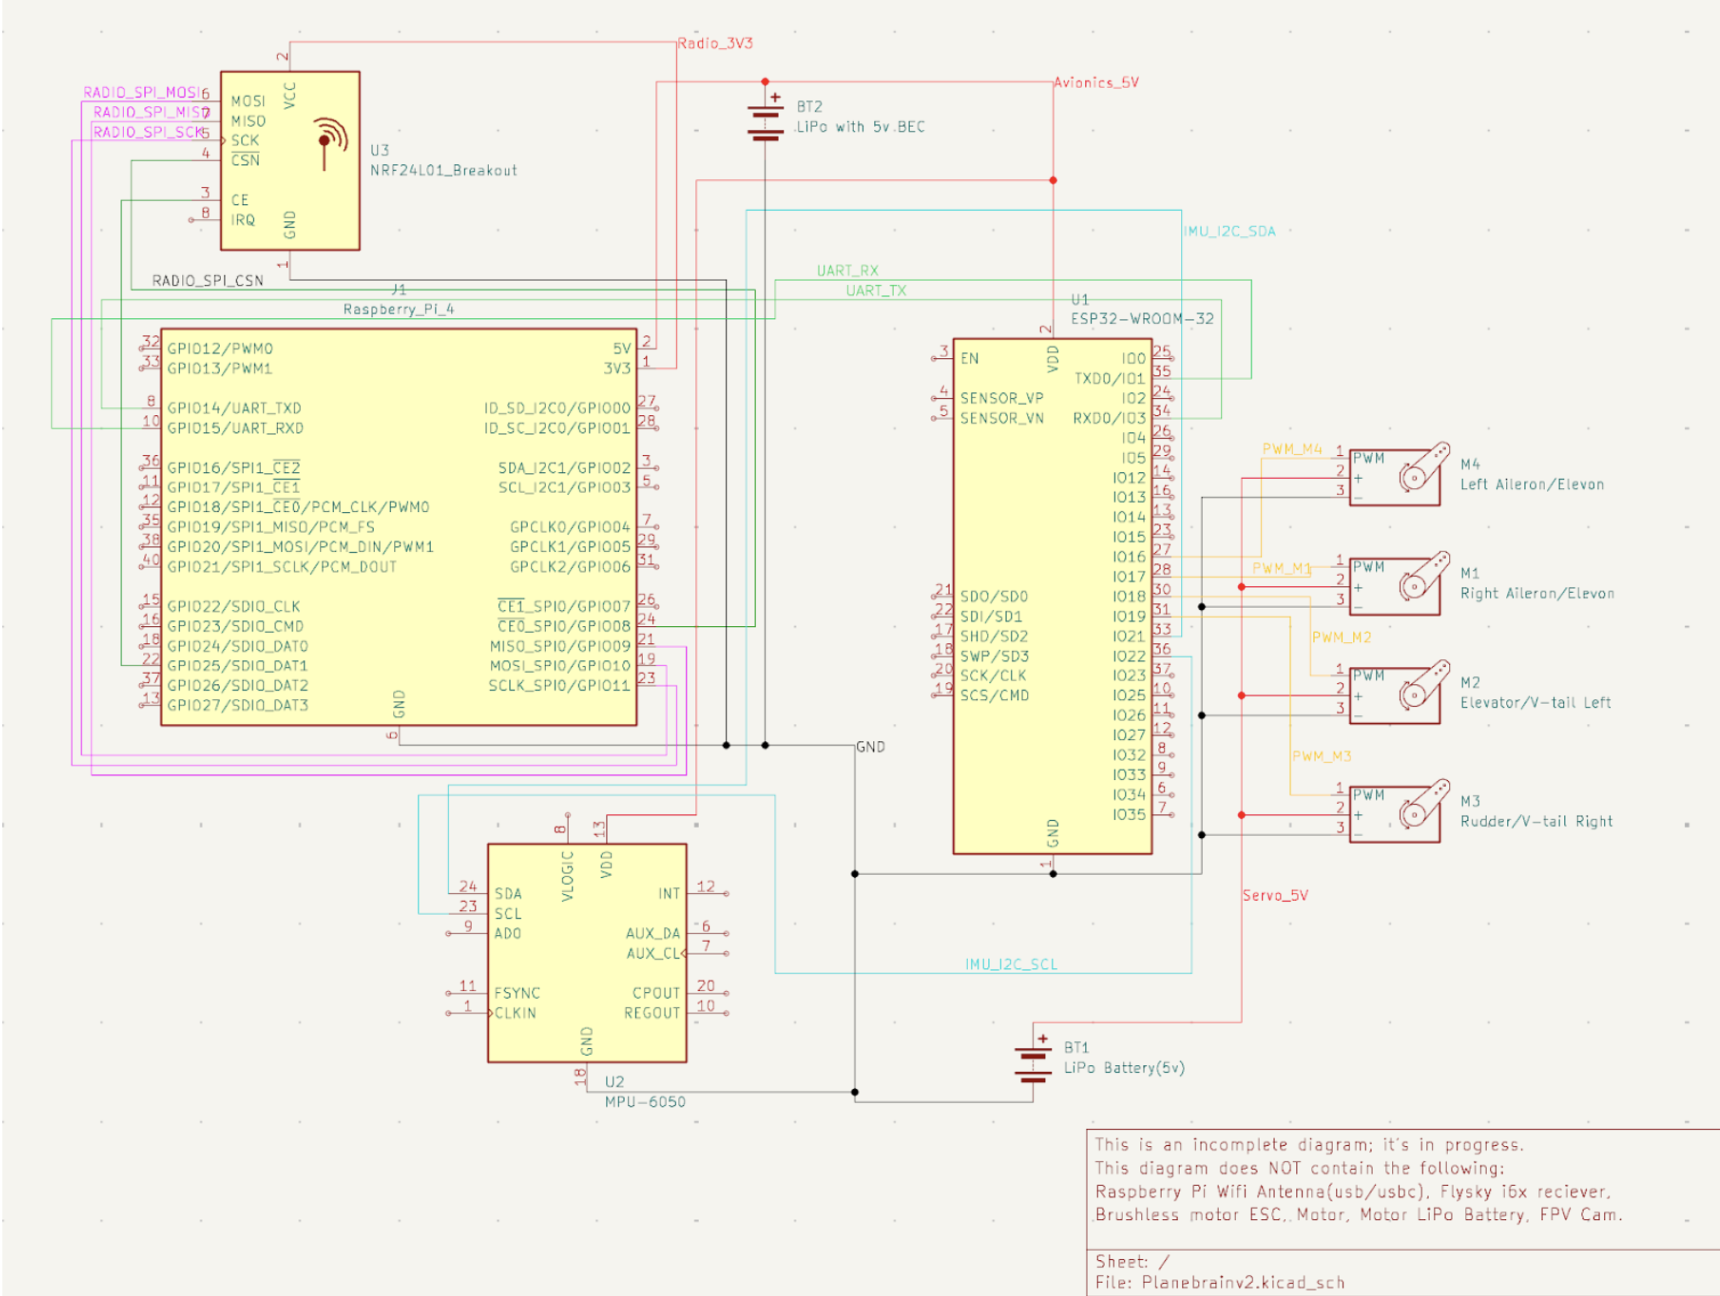
Planebrain
Some flight computer autonomy and telemetry work on a Raspberry Pi and ESP32.
REALTIME CONTROLSC/C++TELEMETRY
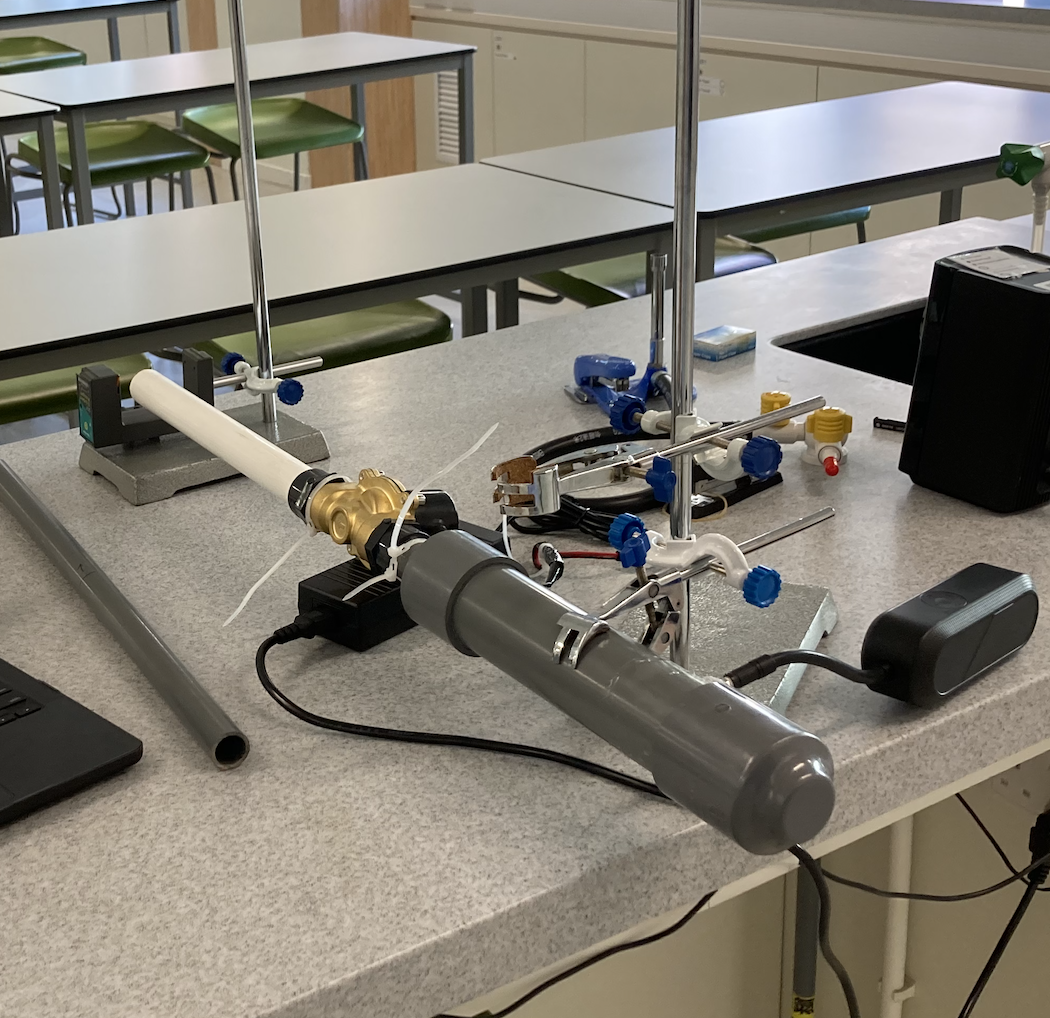
Pneumatic Launchers
Optimizing projectile launching speeds for boba and putty. For science.
FLUID DYNAMICSTESTINGCAD

Fitness Tracker
A hybrid wearable/app prototype for fitness tracking
COMPUTER VISIONRAPID PROTOTYPINGESP32